Multi-agent consensus
APSC 200, Queen's•Fall 2025
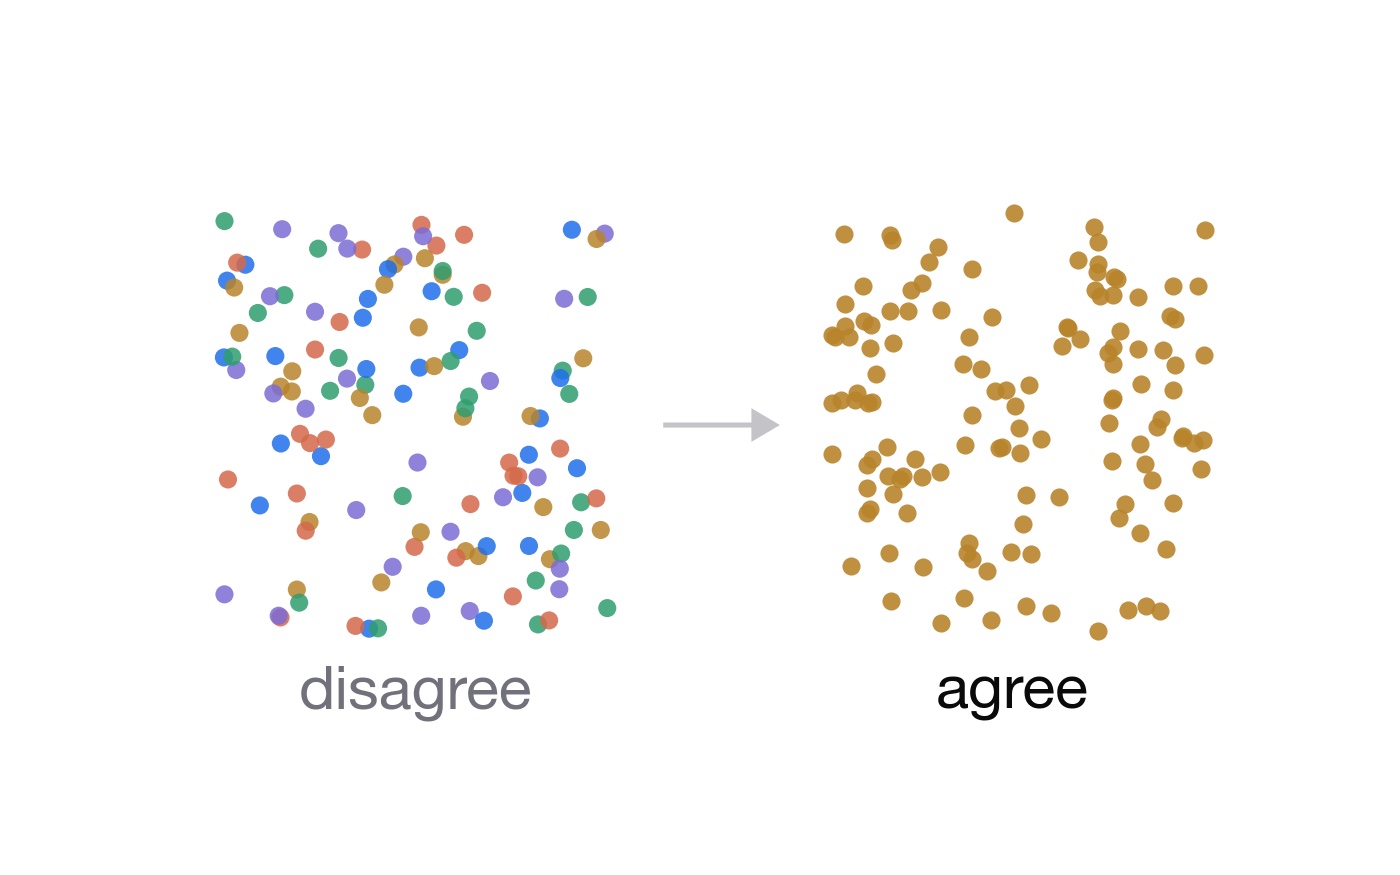
A group of simulated agents each begin with their own noisy estimate of a single number. No agent can see all the estimates, and each one can only exchange values with its nearest neighbours.
The Graph Laplacian consensus algorithm has every agent repeatedly average its value with those of its neighbours. After enough rounds, all the agents converge on the same number.
- Course
- APSC 200, Queen's University
- Method
- Graph Laplacian consensus
- Tools
- MATLAB, Python
- Term
- Fall 2025
- Source
- Coursework, built on the template provided with the course